
Learning for Intelligent Robotic Agents
Welcome to LiRA, where we focus on developing embodied AI agents. Unlike traditional passive AI systems, we specialize in crafting active AI agents capable of understanding and dynamically interacting with the physical world, much like humans do. Our goal extends to the seamless coexistence and collaboration between humans and robots, envisioning a future where these entities work harmoniously together. Drawing from an interdisciplinary toolkit, our research leverages methodologies from reinforcement learning, machine learning, deep learning, optimization, and probabilistic inference.
news
| Jul 21, 2026 | LiRA Lab participated in the 7th Turkish Robotics Conference held at Koç University, Istanbul, on July 19–21, 2026. Ece Kunduracioglu and Huzaifa Salahuddin delivered workshop presentations on behalf of Asst. Prof. Özgür S. Öğüz on the first day, while Asst. Prof. Öğüz gave a talk on the final day. Several lab members also presented their research during the poster sessions. |
|---|---|
| Jul 17, 2026 | Our paper, “CoRAL: Contact-Rich Adaptive LLM-based Control for Robotic Manipulation”, by Berk Çiçek, Mert Kaan Er, and Özgür S. Öğüz, was published in the proceedings of Robotics: Science and Systems (RSS 2026). |
| Jul 11, 2026 | Our paper, “Lagrangian Perturbation Diffusion Steering: Latent Reinforcement Learning for Generative Policies”, by Hikmet Şimşir and Özgür S. Öğüz, was published in the proceedings of the 43rd International Conference on Machine Learning (ICML 2026). |
| Jun 30, 2026 | Our paper, “Uncertainty-Aware Safety Propagation Critics for Safe Reinforcement Learning”, by Kutay Demiray, Efe Eren Ceyani, and Özgür S. Öğüz, was published in Transactions on Machine Learning Research (TMLR) in June 2026. |
selected publications
-
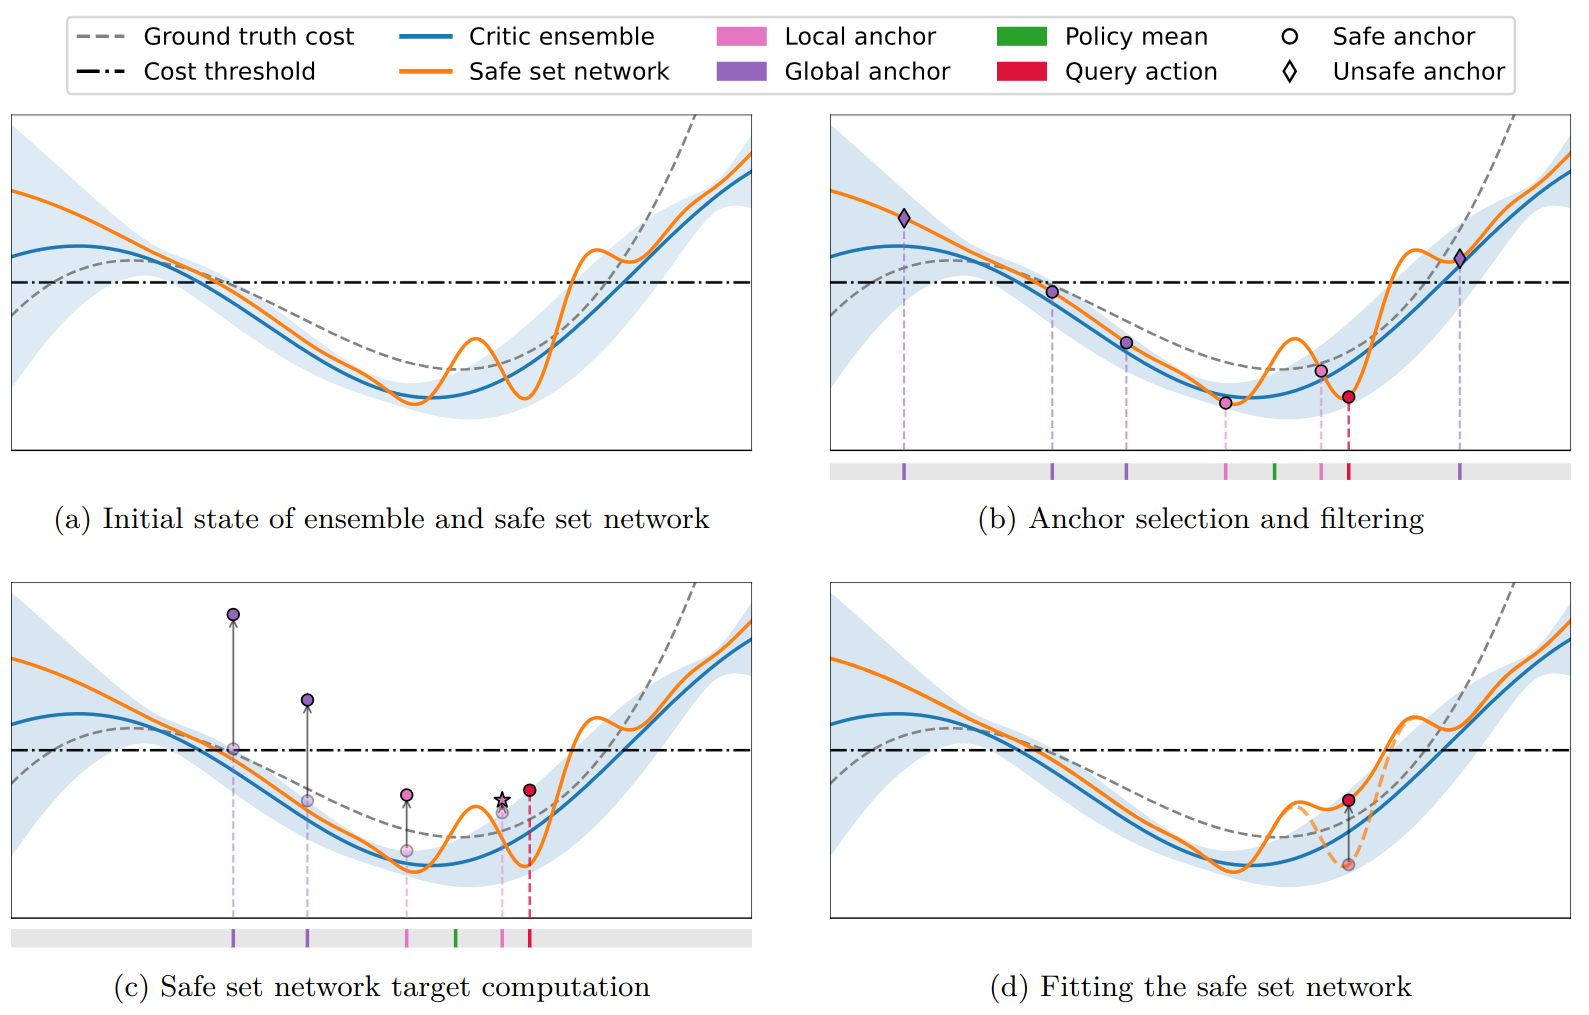 Uncertainty-Aware Safety Propagation Critics for Safe Reinforcement LearningTransactions on Machine Learning Research, 2026
-
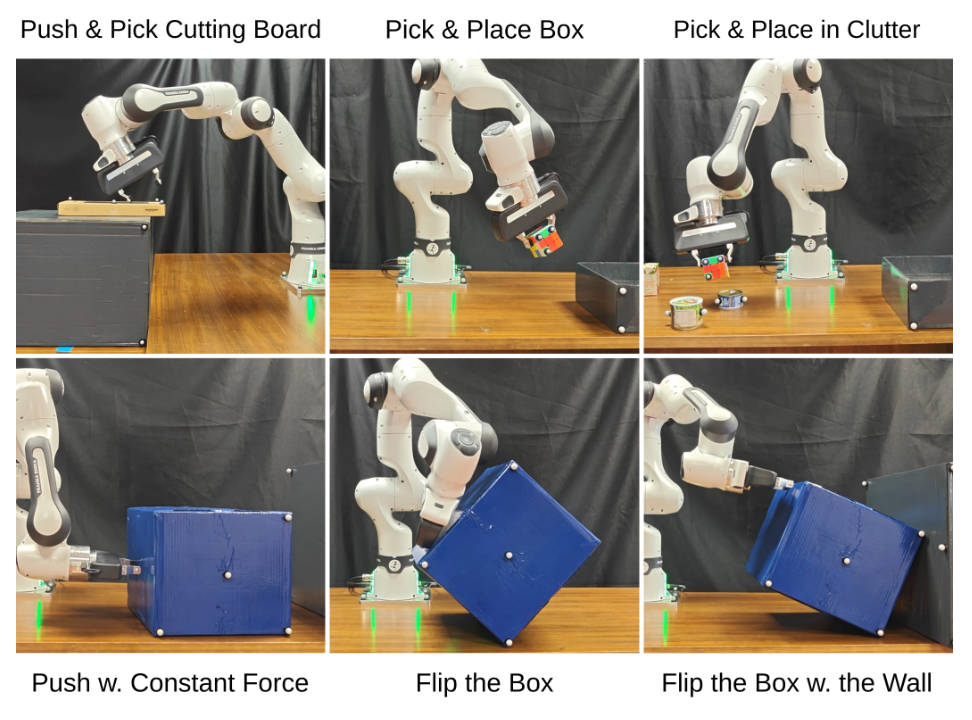 CoRAL: Contact-Rich Adaptive LLM-based Control for Robotic ManipulationRSS 2026 Robotics: Science and Systems 2026, 2026
-
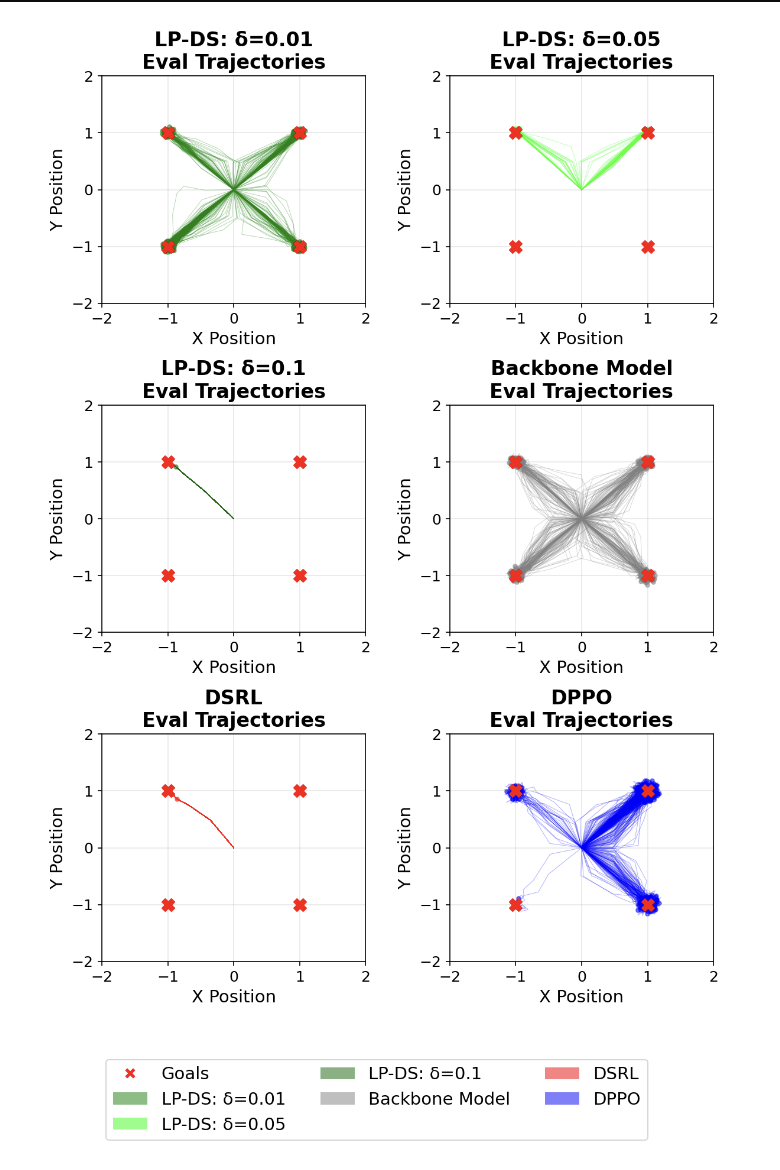 Lagrangian Perturbation Diffusion Steering: Latent Reinforcement Learning for Generative PoliciesICML 2026 Forty-Third International Conference on Machine Learning, 2026
-
 MO-SeGMan: Rearrangement Planning Framework for Multi Objective Sequential and Guided Manipulation in Constrained EnvironmentsarXiv preprint arXiv:2511.01476, 2025
-
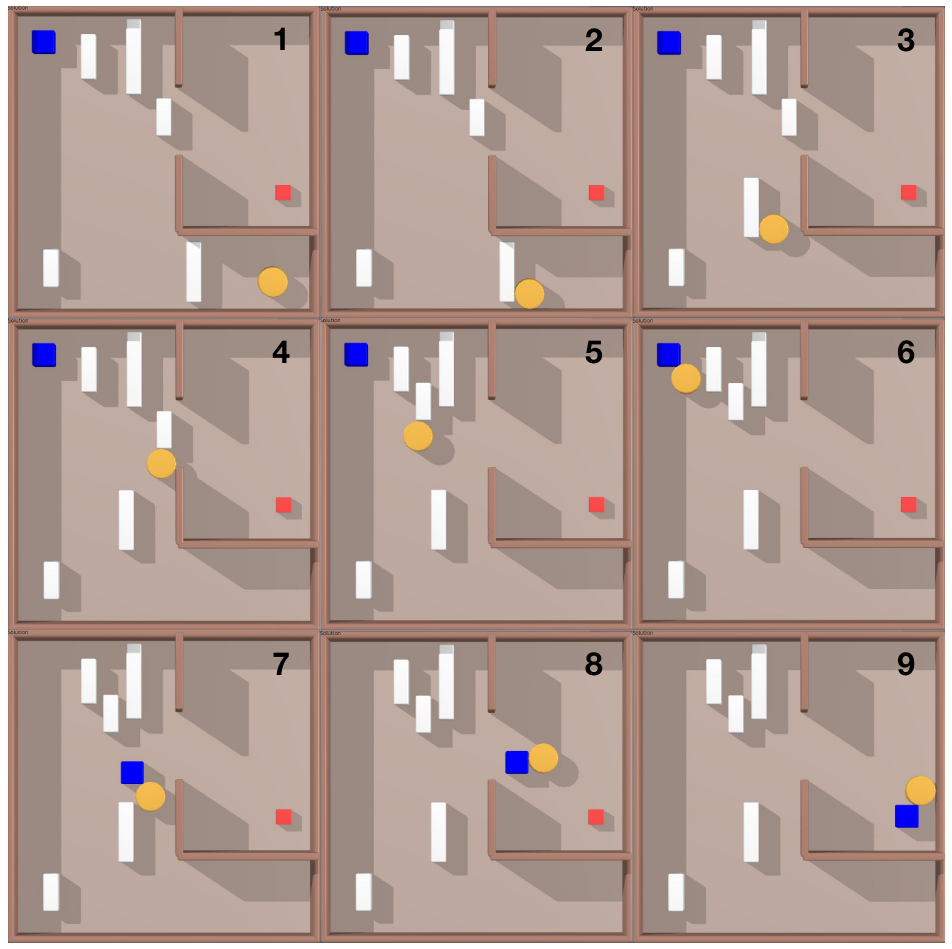 SeGMan: Sequential and Guided Manipulation Planner for Robust Planning in 2D Constrained Environments2025
-
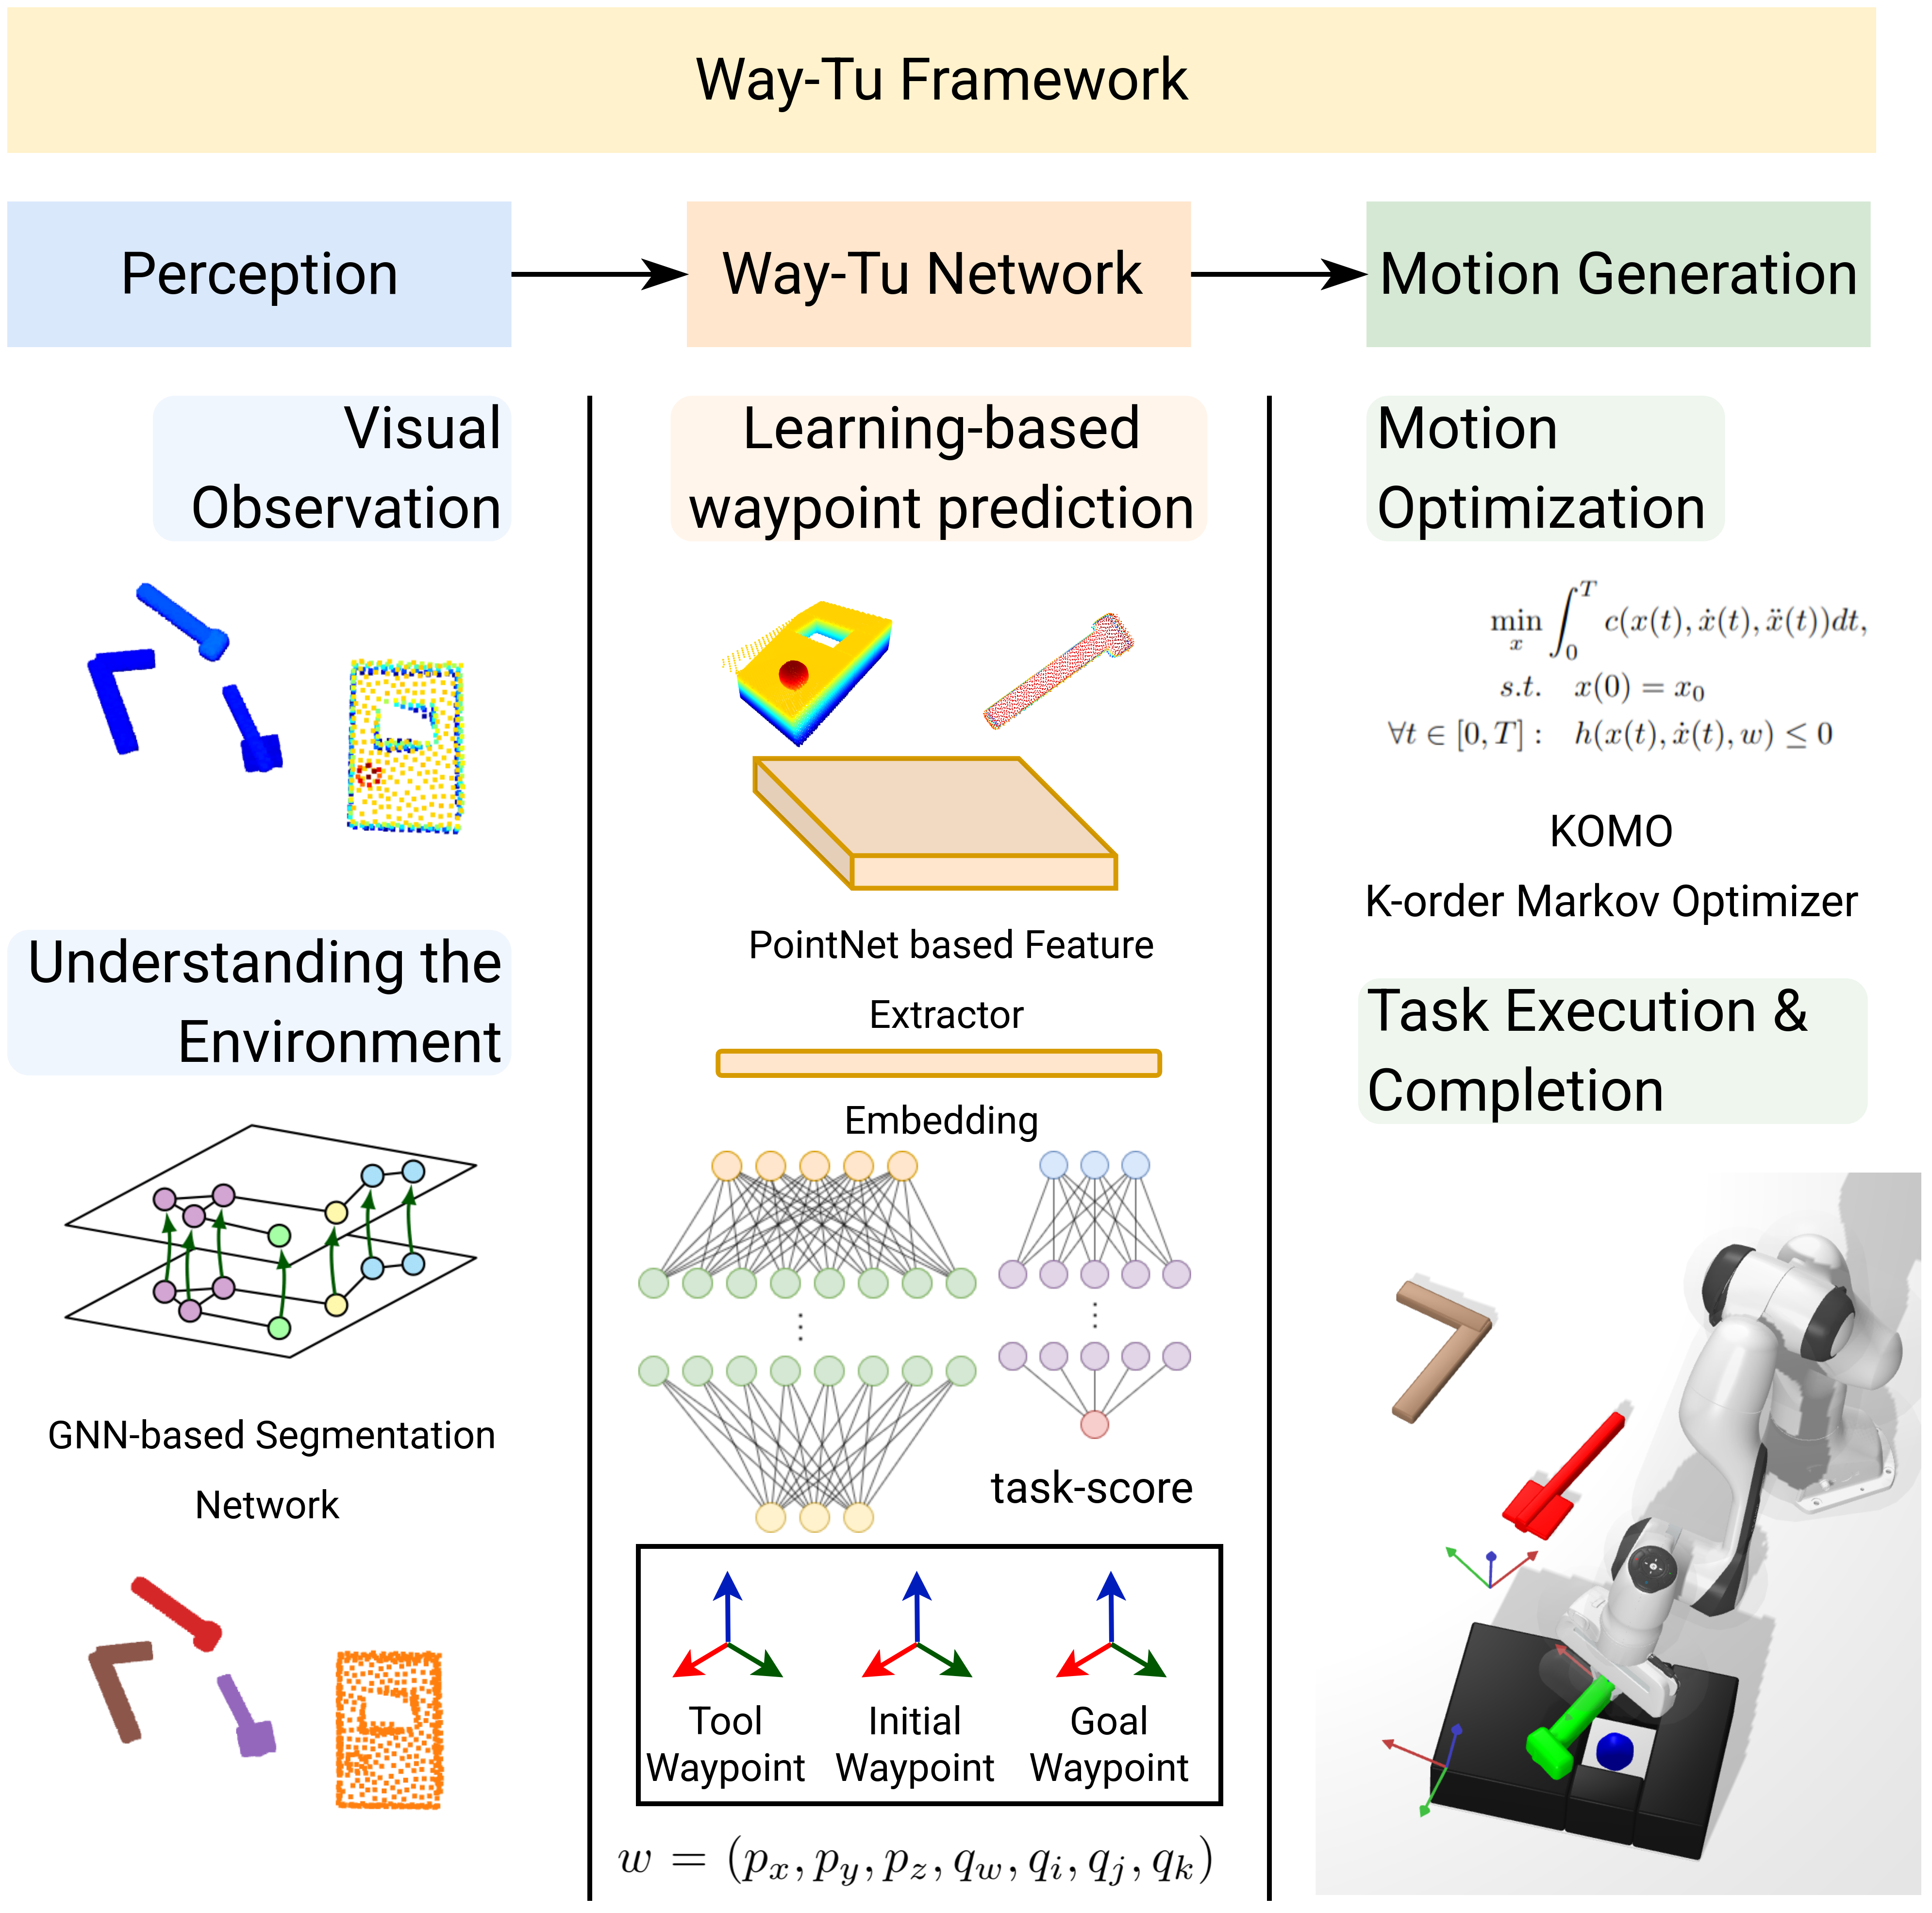 Way-Tu: A Framework for Tool Selection and Manipulation Using Waypoint RepresentationsIn Dexterous Manipulation: Learning and Control with Diverse Modalities , 2025
-
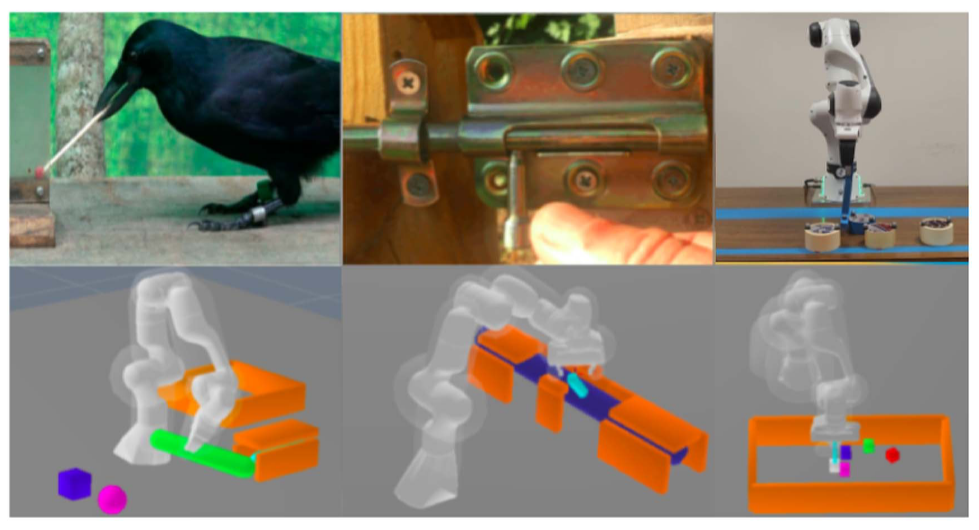 H-MaP: An Iterative and Hybrid Sequential Manipulation PlannerIEEE Robotics and Automation Letters, 2025


Bilkent University
Department of Computer Engineering
Cankaya 06800 Ankara